
 Introduction
In part one of this article, I described how to write an interpreter for raw GPS NMEA data. The article included source code in VB.NET which harnessed the power of GPS satellites to determine the current location, synchronize the computer clock to atomic time, and point to a satellite on a cloudy day. The interpreter also works with hand-held devices and supports international developers. Yet, the interpreter was really not suitable for commercial use because it did not monitor precision. Without precision, an application could end up making unintelligent business decisions such as accidentally telling a driver to turn left into an alley, or worse. In this second part, I'll cover precision in detail and talk about what it takes to make GPS applications smart enough for in-car navigation and reliable enough for commercial use.
Causes of Precision Error
There are several phenomenon which can cause poor precision. For example, when satellite radio signals are transmitted, they are distorted by the troposphere and especially the ionosphere. In fact, satellites very low on the horizon are not good for getting a fix because the signals travel through so much of the atmosphere. Some GPS devices may even exclude these satellites from a fix to avoid the precision problems they would cause.
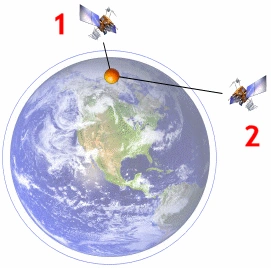
Fortunately, atmospheric distortion can be measured and corrected for the most part. This is achieved by the use of GPS ground stations, fixed locations which constantly measure distortions in satellite radio signals. Calculated corrections are then broadcasted by radio which, when combined with the actual satellite signal, give a GPS receiver the ability to correct distortions in real-time.
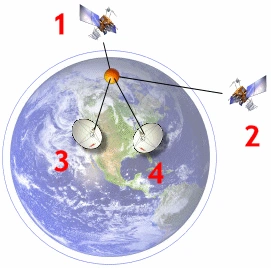
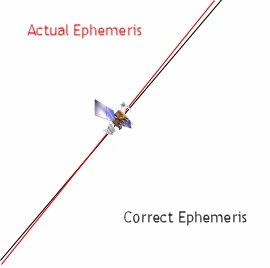
Precision errors can be compounded by slight inaccuracies in each satellite's "ephemeris". Ephemeris is a table giving the coordinates of a celestial body over time. If the satellite's actual course deviates from its ephemeris, precision can be further diluted. This sort of error can only be corrected by firing small rockets on the satellites themselves. Adjustments are transmitted from the GPS Master Control Station at Schriever Air Force Base in Colorado Springs, Colorado.
As I covered in part one of this article, each GPS satellite has four on-board atomic clocks: two cesium atomic clocks and two rubidium atomic clocks which are accurate to 1 second per 300,000 years! Still, even microfractions of a second error in these clocks can cause positional error because distance is measured at the speed of light. The Master Control Station keeps these errors at a minimum by uploading corrective information to satellites twice a day, every day.
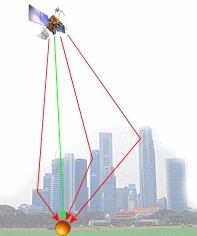
The last detriment to GPS precision is an effect called "multipath", which is an effect caused when a receiver receives not only the satellite's signal, but additional signals which bounced off buildings and other obstacles. Deflected signals take a longer path to the receiver and are thus delayed. If they are used by the receiver, the measured distance to a satellite is overestimated, resulting in inaccurate multilateration. More advanced receivers solve multipath problems by utilizing only the first signal detected (which is the most direct path from the satellite), then discarding any delayed signals.
Solving all of these precision problems is done by using more sophisticated GPS receivers which use real-time correction data such as WAAS (for North America) and EGNOS (for Europe). Yet, these problems cause relatively small inaccuracies when compared with Geometric Dilution of Precision, which can cause a receiver to be inaccurate by more than an American football field. Fortunately, Geometric DOP is the easiest to manage with the right programming techniques.
Geometric Dilution of Precision
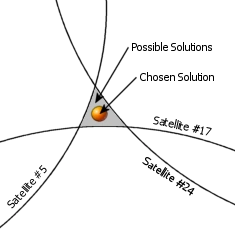
GPS devices calculate your position using a technique called "3-D multilateration", which is the process of figuring out where several spheres intersect. In the case of GPS, each sphere has a satellite at its center; the radius of the sphere is the calculated distance from the satellite to the GPS device. Ideally, these spheres would intersect at exactly one point, causing there to be only one possible solution to the current location, but in reality, the intersection forms more of an oddly-shaped area. The device could be located within any point in the area, forcing devices to choose from many possibilities. Figure 2-4 shows such an area created from three satellites (using part one's $GPGSV sentence). The current location could be any point within the gray-colored area. Precision is said to be "diluted" when the area grows larger, which leads to this article's focus: dilution of precision. The monitoring and control of dilution of precision (or DOP for short) is the key to writing high-precision applications.
DOP values are reported in three types of measurements: horizontal, vertical, and mean. Horizontal DOP (or HDOP) measures DOP as it relates to latitude and longitude. Vertical DOP (or VDOP) measures precision as it relates to altitude. Mean DOP, also known as Position DOP (PDOP), gives an overall rating of precision for latitude, longitude and altitude. Each DOP value is reported as a number between one and fifty where fifty represents very poor precision and one represents ideal accuracy. Table 2-1 lists what I believe to be an accurate breakdown of DOP values.
| DOP | Rating | Description |
| 1 | Ideal | This is the highest possible confidence level to be used for applications demanding the highest possible precision at all times. |
| 2-3 | Excellent | At this confidence level, positional measurements are considered accurate enough to meet all but the most sensitive applications. |
| 4-6 | Good | Represents a level that marks the minimum appropriate for making business decisions. Positional measurements could be used to make reliable in-route navigation suggestions to the user. |
| 7-8 | Moderate | Positional measurements could be used for calculations, but the fix quality could still be improved. A more open view of the sky is recommended. |
| 9-20 | Fair | Represents a low confidence level. Positional measurements should be discarded or used only to indicate a very rough estimate of the current location. |
| 21-50 | Poor | At this level, measurements are inaccurate by as much as half a football field and should be discarded. |
Table 2-1: Jon's interpretation of dilution of precision values.
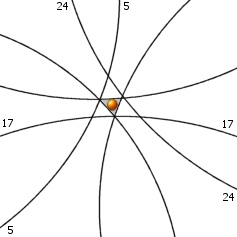
Looking again at figure 2-4, three satellites created a large area of possible solutions. This situation could be improved by two factors: adding more satellites to the fix, and using satellites evenly distributed throughout the sky. What would figure 2-4 look like if the situation was improved like this? Figure 2-5 shows Figure 2-4 after three more evenly-distributed satellites have been added.
Determining Precision Needs
Now that the mechanics of precision have been explained, the next step is to figure out how to determine the actual precision needs of an application. As a general rule of thumb, an HDOP value of six or less is recommended for any application which makes suggestions to the user based on the current location. For example, in-car navigation programs which tell the user to "turn left now" should ignore positional measurements when HDOP is greater than six. But is six really good enough? How can developers figure out which HDOP values to use for their own applications? To answer these kinds of questions, I like to use a simple formula:
Accuracy of GPS Device * DOP = Maximum Allowable Error
This formula uses DOP as a factor of error which, when combined with the accuracy of the GPS device being used, yields the maximum error allowed by a level of DOP in the form of a specific, measurable distance. Another general rule of thumb is that typical consumer GPS devices are capable of between 5-7 meters of accuracy without enhancements like DGPS or WAAS, or an average of six meters. Using the in-car navigation HDOP of six and a typical GPS device, the maximum error allowed is 6m * 6 = 36 meters, or 118 feet. Given that a downtown city block is roughly 475 feet square, the maximum allowable error is about a quarter of a city block. This is precise enough to make sure that the driver turns at the correct road. On the other hand, an HDOP of twelve results in an allowable error of half a city block (237 feet), which could cause drivers to turn down an alley accidentally. So, using the formula, it is possible to use an HDOP greater than six for in-car navigation, but not by much.
The trick to using this formula is researching real-world distances, especially the smallest important distances. To demonstrate, take a look at golf. Does golf require more precision than in-car navigation? A golf program needs to tell the user which golf club to use in order to make the best shot. Some research into important golf distances finds that for most players, there is a regular distance interval between clubs of about 10-15 yards. Therefore, a golf program needs no more than 10 yards (9.1 meters) of allowable error to consistently suggest the right club. When 9.1 meters is put into the formula as Maximum Allowable Error, the maximum HDOP comes out to 3. So, golfing applications require about twice the precision as in-car navigation systems.
Why not skip the formulas and always enforce an HDOP of one? This looks like a reasonable practice, but greater precision requires greater satellite visibility. An in-car navigation system will probably not get an HDOP of one (or even three) downtown because signals are being obscured by buildings. If the enforced HDOP is too small, the application will throw out too many positional readings and just sit there while the driver loses patience. Golfing applications, on the other hand, can realistically enforce a small HDOP because they operate outdoors. The golfer's PDA is likely to have plenty of open sky enough to pick up several evenly-distributed satellites, unless their ball is in the middle of the woods, in which case they're on their own.
To summarize, successful GPS software developers will use the formula to determine the greatest possible DOP number. This will ensure that the application minimizes most problems due to inaccuracy while at the same time allowing the application to function in the poorest possible satellite visibility conditions. This practice will maximize the value and versatility of any GPS application.
Enforcing Precision
Now that the precision needs of a GPS application can be determined, it's time to find out what source code is necessary to extract and enforce maximum DOP values. All DOP measurements are packaged into the $GPGSA sentence every few seconds. Here is a sample of a $GPGSA sentence:
$GPGSA,A,3,11,29,07,08,5,17,24,,,,,,2.3,1.2,2.0*30
A skillful GPS application developer could know if positional readings are precise enough to use just by looking at one $GPGSA sentence. Again, the best DOP ratings occur when there are several satellites involved in a fix and the satellites are evenly distributed throughout the sky and at separate elevations -– hitting the GPS device from all angles, so to speak.
The last three words of this sentence are 2.3, 1.2, and 2.0, representing mean, horizontal and vertical DOP, respectively. This sentence represents a high-precision environment (suitable enough for both golfing and driving). Using the final listing from part I of this article (Listing 1-8), a method called ParseGPGSA is added which extracts DOP values and reports them via three events: HDOPReceived, VDOPReceived and PDOPReceived.
[C#]
//*********************************************************************
//** A high-precision NMEA interpreter
//** Written by Jon Person, author of "GPS.NET" (www.gpsdotnet.com)
//*********************************************************************
using System;
using System.Globalization;
public class NmeaInterpreter
{
// Represents the EN-US culture, used for numers in NMEA sentences
public static CultureInfo NmeaCultureInfo = new CultureInfo("en-US");
// Used to convert knots into miles per hour
public static double MPHPerKnot = double.Parse("1.150779",
NmeaCultureInfo);
#region Delegates
public delegate void PositionReceivedEventHandler(string latitude,
string longitude);
public delegate void DateTimeChangedEventHandler(System.DateTime dateTime);
public delegate void BearingReceivedEventHandler(double bearing);
public delegate void SpeedReceivedEventHandler(double speed);
public delegate void SpeedLimitReachedEventHandler();
public delegate void FixObtainedEventHandler();
public delegate void FixLostEventHandler();
public delegate void SatelliteReceivedEventHandler(
int pseudoRandomCode, int azimuth, int elevation,
int signalToNoiseRatio);
public delegate void HDOPReceivedEventHandler(double value);
public delegate void VDOPReceivedEventHandler(double value);
public delegate void PDOPReceivedEventHandler(double value);
#endregion
#region Events
public event PositionReceivedEventHandler PositionReceived;
public event DateTimeChangedEventHandler DateTimeChanged;
public event BearingReceivedEventHandler BearingReceived;
public event SpeedReceivedEventHandler SpeedReceived;
public event SpeedLimitReachedEventHandler SpeedLimitReached;
public event FixObtainedEventHandler FixObtained;
public event FixLostEventHandler FixLost;
public event SatelliteReceivedEventHandler SatelliteReceived;
public event HDOPReceivedEventHandler HDOPReceived;
public event VDOPReceivedEventHandler VDOPReceived;
public event PDOPReceivedEventHandler PDOPReceived;
#endregion
// Processes information from the GPS receiver
public bool Parse(string sentence)
{
// Discard the sentence if its checksum does not match our
// calculated checksum
if (!IsValid(sentence)) return false;
// Look at the first word to decide where to go next
switch (GetWords(sentence)[0])
{
case "$GPRMC":
// A "Recommended Minimum" sentence was found!
return ParseGPRMC(sentence);
case "$GPGSV":
// A "Satellites in View" sentence was received
return ParseGPGSV(sentence);
case "$GPGSA":
return ParseGPGSA(sentence);
default:
// Indicate that the sentence was not recognized
return false;
}
}
// Divides a sentence into individual words
public string[] GetWords(string sentence)
{
return sentence.Split(',');
}
// Interprets a $GPRMC message
public bool ParseGPRMC(string sentence)
{
// Divide the sentence into words
string[] Words = GetWords(sentence);
// Do we have enough values to describe our location?
if (Words[3] != "" && Words[4] != "" &&
Words[5] != "" && Words[6] != "")
{
// Yes. Extract latitude and longitude
// Append hours
string Latitude = Words[3].Substring(0, 2) + "°";
// Append minutes
Latitude = Latitude + Words[3].Substring(2) + "\"";
// Append hours
Latitude = Latitude + Words[4]; // Append the hemisphere
string Longitude = Words[5].Substring(0, 3) + "°";
// Append minutes
Longitude = Longitude + Words[5].Substring(3) + "\"";
// Append the hemisphere
Longitude = Longitude + Words[6];
// Notify the calling application of the change
if(PositionReceived != null)
PositionReceived(Latitude, Longitude);
}
// Do we have enough values to parse satellite-derived time?
if (Words[1] != "")
{
// Yes. Extract hours, minutes, seconds and milliseconds
int UtcHours = Convert.ToInt32(Words[1].Substring(0, 2));
int UtcMinutes = Convert.ToInt32(Words[1].Substring(2, 2));
int UtcSeconds = Convert.ToInt32(Words[1].Substring(4, 2));
int UtcMilliseconds = 0;
// Extract milliseconds if it is available
if (Words[1].Length > 7)
{
UtcMilliseconds = Convert.ToInt32(
float.Parse(Words[1].Substring(6), NmeaCultureInfo) * 1000);
}
// Now build a DateTime object with all values
System.DateTime Today = System.DateTime.Now.ToUniversalTime();
System.DateTime SatelliteTime = new System.DateTime(Today.Year,
Today.Month, Today.Day, UtcHours, UtcMinutes, UtcSeconds,
UtcMilliseconds);
// Notify of the new time, adjusted to the local time zone
if(DateTimeChanged != null)
DateTimeChanged(SatelliteTime.ToLocalTime());
}
// Do we have enough information to extract the current speed?
if (Words[7] != "")
{
// Yes. Parse the speed and convert it to MPH
double Speed = double.Parse(Words[7], NmeaCultureInfo) *
MPHPerKnot;
// Notify of the new speed
if(SpeedReceived != null)
SpeedReceived(Speed);
// Are we over the highway speed limit?
if (Speed > 55)
if(SpeedLimitReached != null)
SpeedLimitReached();
}
// Do we have enough information to extract bearing?
if (Words[8] != "")
{
// Indicate that the sentence was recognized
double Bearing = double.Parse(Words[8], NmeaCultureInfo);
if(BearingReceived != null)
BearingReceived(Bearing);
}
// Does the device currently have a satellite fix?
if (Words[2] != "")
{
switch (Words[2])
{
case "A":
if(FixObtained != null)
FixObtained();
break;
case "V":
if(FixLost != null)
FixLost();
break;
}
}
// Indicate that the sentence was recognized
return true;
}
// Interprets a "Satellites in View" NMEA sentence
public bool ParseGPGSV(string sentence)
{
int PseudoRandomCode = 0;
int Azimuth = 0;
int Elevation = 0;
int SignalToNoiseRatio = 0;
// Divide the sentence into words
string[] Words = GetWords(sentence);
// Each sentence contains four blocks of satellite information.
// Read each block and report each satellite's information
int Count = 0;
for (Count = 1; Count <= 4; Count++)
{
// Does the sentence have enough words to analyze?
if ((Words.Length - 1) >= (Count * 4 + 3))
{
// Yes. Proceed with analyzing the block.
// Does it contain any information?
if (Words[Count * 4] != "" && Words[Count * 4 + 1] != ""
&& Words[Count * 4 + 2] != "" && Words[Count * 4 + 3] != "")
{
// Yes. Extract satellite information and report it
PseudoRandomCode = System.Convert.ToInt32(Words[Count * 4]);
Elevation = Convert.ToInt32(Words[Count * 4 + 1]);
Azimuth = Convert.ToInt32(Words[Count * 4 + 2]);
SignalToNoiseRatio = Convert.ToInt32(Words[Count * 4 + 3]);
// Notify of this satellite's information
if(SatelliteReceived != null)
SatelliteReceived(PseudoRandomCode, Azimuth,
Elevation, SignalToNoiseRatio);
}
}
}
// Indicate that the sentence was recognized
return true;
}
// Interprets a "Fixed Satellites and DOP" NMEA sentence
public bool ParseGPGSA(string sentence)
{
// Divide the sentence into words
string[] Words = GetWords(sentence);
// Update the DOP values
if (Words[15] != "")
{
if(PDOPReceived != null)
PDOPReceived(double.Parse(Words[15], NmeaCultureInfo));
}
if (Words[16] != "")
{
if(HDOPReceived != null)
HDOPReceived(double.Parse(Words[16], NmeaCultureInfo));
}
if (Words[17] != "")
{
if(VDOPReceived != null)
VDOPReceived(double.Parse(Words[17], NmeaCultureInfo));
}
return true;
}
// Returns True if a sentence's checksum matches the
// calculated checksum
public bool IsValid(string sentence)
{
// Compare the characters after the asterisk to the calculation
return sentence.Substring(sentence.IndexOf("*") + 1) ==
GetChecksum(sentence);
}
// Calculates the checksum for a sentence
public string GetChecksum(string sentence)
{
// Loop through all chars to get a checksum
Join the conversation! Your thoughts help the community grow.